


X2 NEO Full-Stack Open Source Humanoid Robot
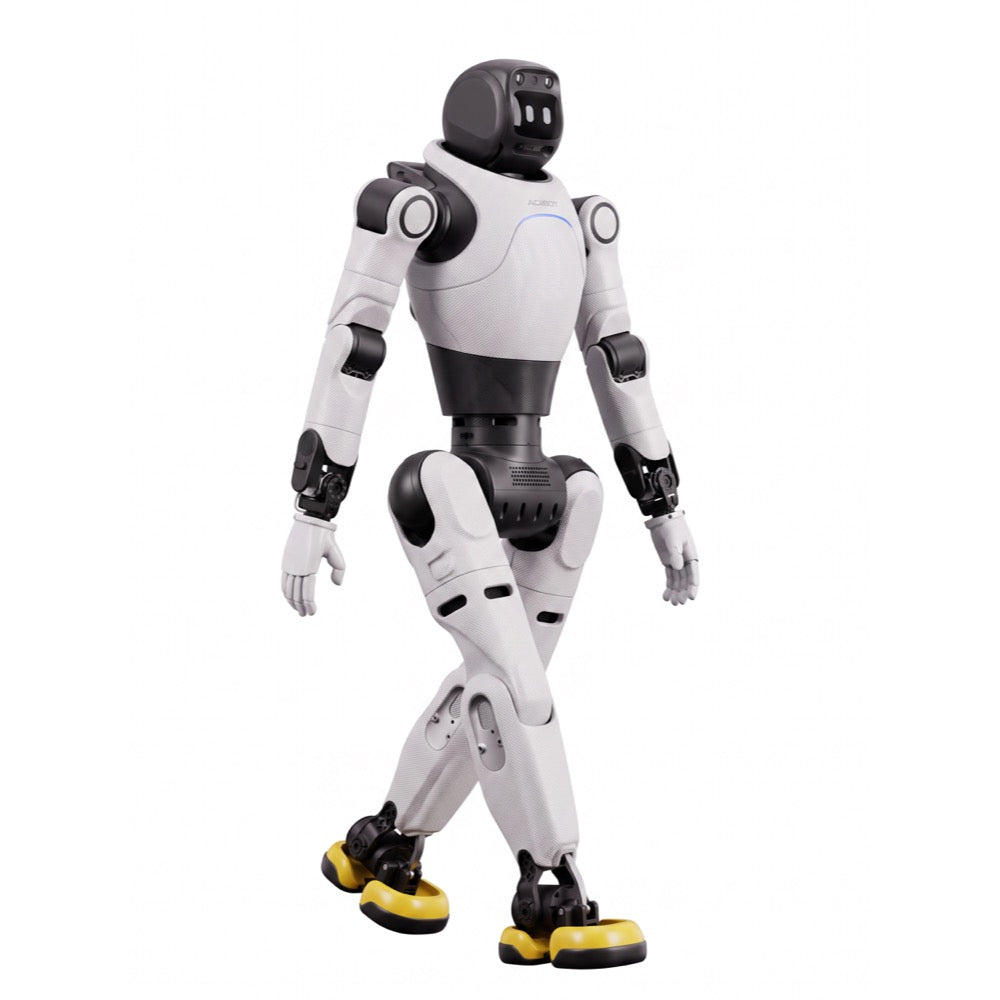
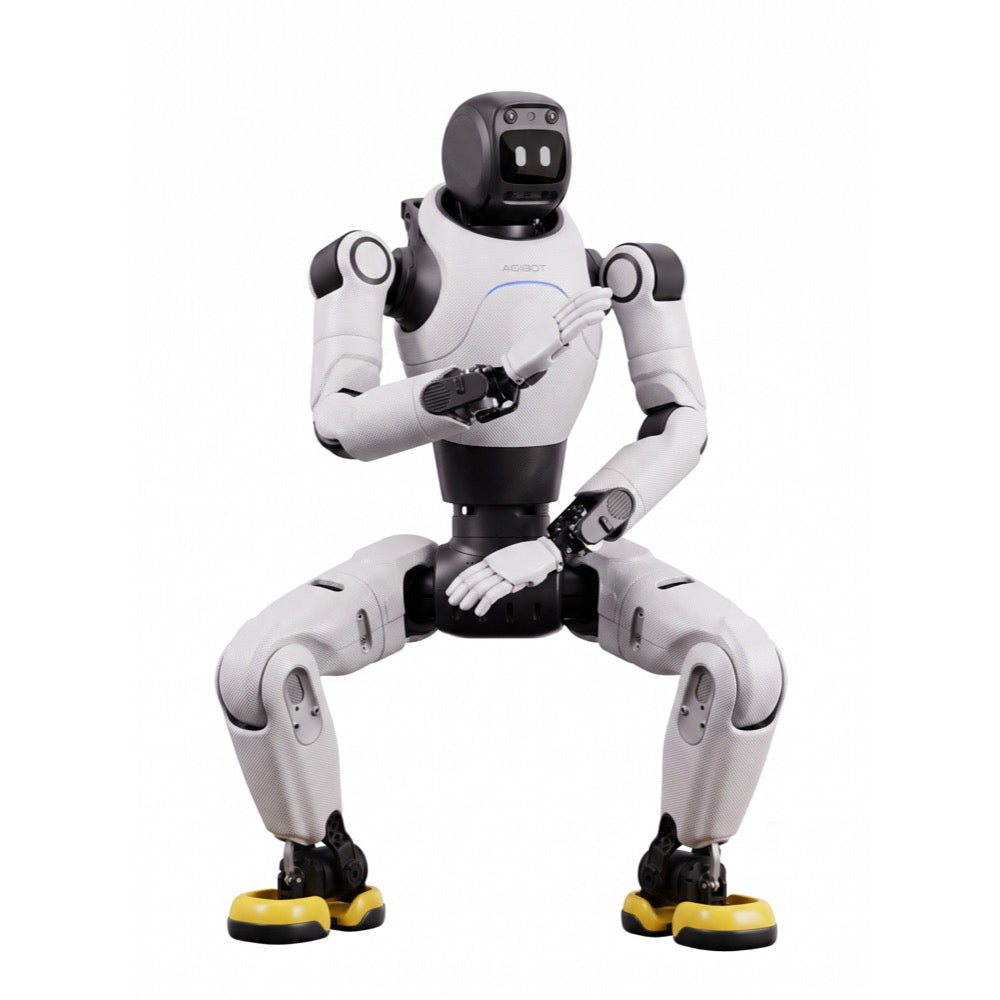
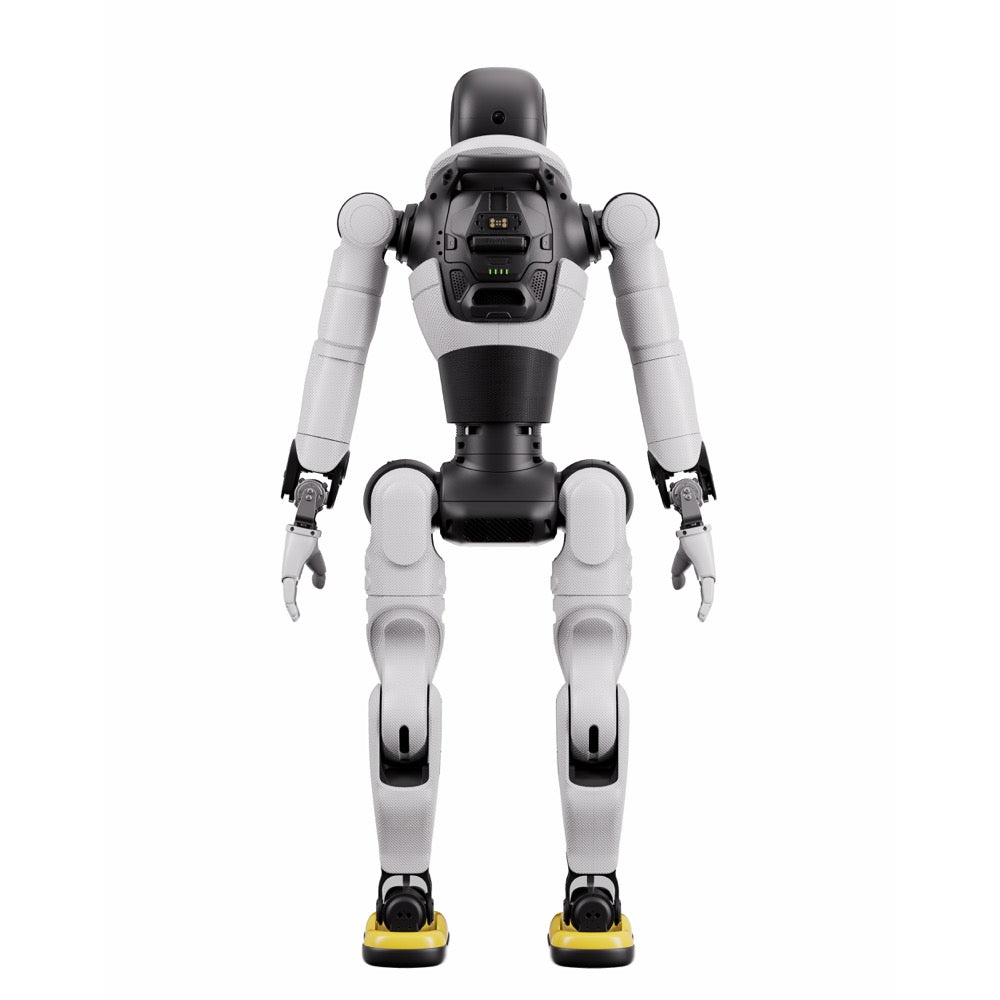
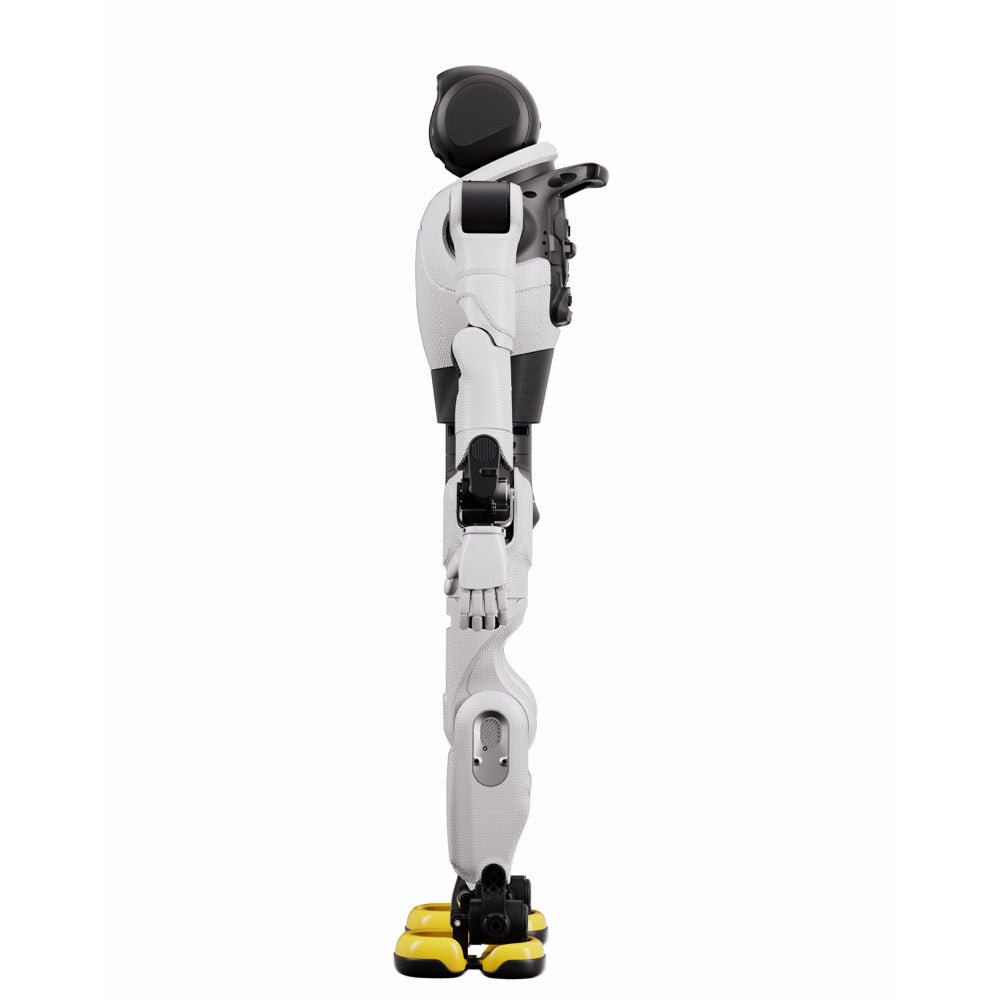
Advanced robotics X2 is a new-generation full-size humanoid robot launched by AGIBOT in 2026, positioned as a "silicon-based star born for the stage". Weighing only 55kg yet delivering 12KW of instantaneous power, it achieves an industry-leading power-to-weight ratio of 0.218KW/kg, enabling high-difficulty maneuvers such as aerial walking. It features a model-grade physique with fully customizable appearance and roles.
Contact



Friendly
Affinity & Human-like Interaction
X2 Supports multimodal interaction including visual, voice, tactile, and facial expression By integrating user gestures, environmental data, and contextual information, it enables advanced intelligent dialogue, delivering natural and seamless communication across diverse application scenarios.

Agile
Agility Lifelike Features
X2 Supports humanoid gait, complex dance routines, as well as head movements synchronized with voice
X2 Offers 25 degrees of freedom, including 3 for the waist. Enables versatile andagile otion, delivering vivid and lifelike expressions.

Intelligent
Intelligent Autonomous Tasks
X2 Supports autonomous navigation walking, proactive obstacleavoidance, and automatic
energy replenishment
Powered by algorithm-driven decision-making
Enabling intelligent operation without relying on remote control.
Technical specifications
1 basic information
- Weight
- Approx.35kg
- Arm Reach
- 558mm excluding end effector
- Dimensions
- 1310mm (H) x 460mm (W) x 210mm (L)
- Excluding End Effector
- -10°C to 40°C
- Height
- Approx. 1.31 m
- Leg Dof Per Leg
- 6
- Neck Degrees Of Freedom
- 0
- Single Arm Degrees Of Freedom
- 5
- Total Active Degrees Of Freedom
- 25
- Waist Dof
- 3
2 communication
- Communication
- Wi-Fi, Bluetooth
3 energy power
- Charger Output
- 54.6V 10A
- Charging Time
- ≤1.5 hours
- Charging Type
- Direct charging, swappable battery
- Charging Voltage
- 100~220V
- Operating Time
- At 0.5 m\/s walking Approx. 2 hours
- Total Battery Capacity
- Approx.500Wh
4 hardware expansion interface
- Power Output
- 12V\/3A ×1 48V\/5A ×1
- Usb Ports
- Type-A ×1 Type-C ×1
5 intelligent control specifications
- Main Compute Board
- RK3588 x2
6 interaction module
- Audio 1 0
- Microphone array, wireless microphone, speaker
- Display
- Interactive screen, lighting effects
7 other
- Handheld Controller
- Option
- Mobile App
- Supported
- Ota Updates
- Supported
8 perception system
- Head Touch Sensor
- Equipped
- Rgb Camera
- Interactive RGB camera
9 performance parameters
- Arm Rated Load
- 5kg
- Chassis Speed
- 1.5m\/s
- Joint Torque Sensors
- Equipped
- Mobility Modes
- Omnidirectional, Crab walk, In-place Rotation
- Payload Capacity
- Max (in specific postures): 3kg Excluding end effector Across full range: ≤1kg Excluding end effector
- Peak Joint Torque
- 120N m
- Walking Speed
- Up to : 1.8 m\/s typical ≤0.8 m\/s Laboratory Environment: ≤2m\/s